Charvi Shukla
👋🏽 Hi! I'm an M.S. student in Computer Science at UC San Diego, specializing in Robotics. I work in the Cognitive Robotics Lab, where my thesis is advised by Professor Henrik I. Christensen. I am interested in studying the intersection of machine learning and robotics, focusing on how large language models can make human-robot interaction more natural and useful.
Before that, I earned B.S. degrees in Mathematics-Computer Science and in Cognitive Science (specialization in Machine Learning and Neural Computation) at UC San Diego.
Email: cshukla [at] ucsd [dot] edu
Industry Experience

Built Otto, an agentic AI system that monitors the robots' computer vision and insights pipeline for anomalies across 10+ BigQuery tables and debugs them with tool-calling sub-agents that query SQL, inspect code, and run shell commands. Deployed on GCP Cloud Run with Pulumi infrastructure-as-code.

Built a build-health quality review dashboard used by 80+ Apple teams, with a React.js frontend and a FastAPI/MongoDB backend. Integrated group-based OIDC authentication and managed Kubernetes deployments across staging and production.
Experimented with retail product recognition improvements by LoRA fine-tuning open-source vision-language models (+38% accuracy) and speeding up inference with vLLM. Designed a multimodal rank-fusion approach that reached 88% accuracy while running ~13x faster and cheaper than the existing method.

Designed a deterministic state machine to enable verification and E2E testing of negotiation workflow
Research
Tourguide Robot
Project SiteA tour guide robot built from a Reachy Mini head on a ROSbot base, with RTAB-Map mapping, AprilTag landmarks, autonomous navigation, and conversation.
Advanced Robotics and Controls Lab @ UCSD
WebsiteI had the opportunity to work as an Undergraduate Student Researcher under the guidance of Dr. Shan Lin on the following projects:
- Surgical Perception Framework (SuPerPM) -- Worked on improving dense matches between point clouds
- Medical LLM Fine Tuning -- LoRA Fine tuning followed by human evaluation
Enhanced Vehicle Identification Using YOLOv8 with Counter-Based Grouping for Improved Real-Time Performance, ICSISCET 2024
Springer Book Series: Algorithms for Intelligent Systems, A. Agrawal and C. Shukla
Projects
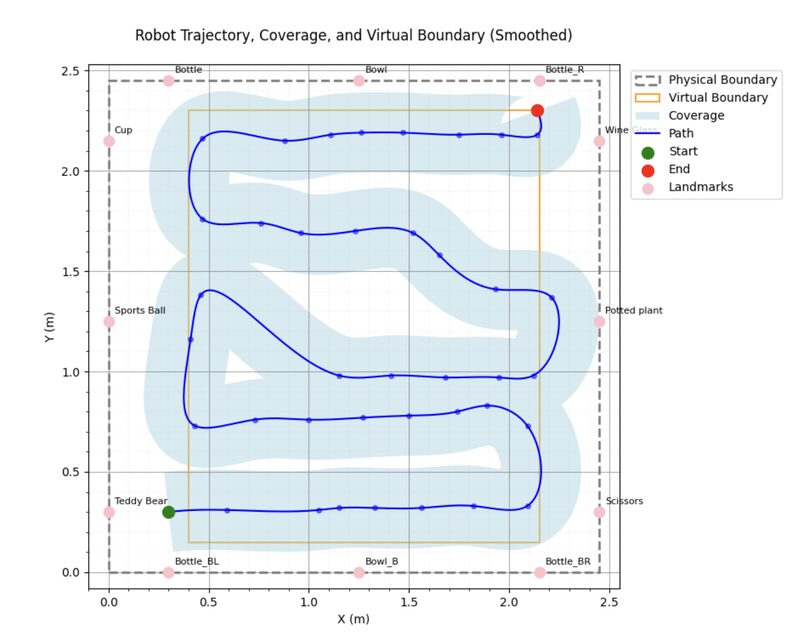
Autonomous Navigation on a Wave Rover
A five-part series building up autonomy on a small differential drive rover with ROS 2, from open-loop control to full area coverage.
- Waypoint navigation: calibrated open-loop Turn–Move–Turn controller (video)
- Closed-loop control: pose correction with natural landmarks detected by YOLOv8 (video 1, video 2)
- EKF SLAM: jointly estimating robot pose and landmark positions on square and octagon trajectories (square, octagon)
- Path planning: A* shortest path on an occupancy grid and safe path planning around obstacles (shortest, safe)
- Coverage: state-machine sweep planner with landmark-based localization for full area coverage (video 1, video 2)
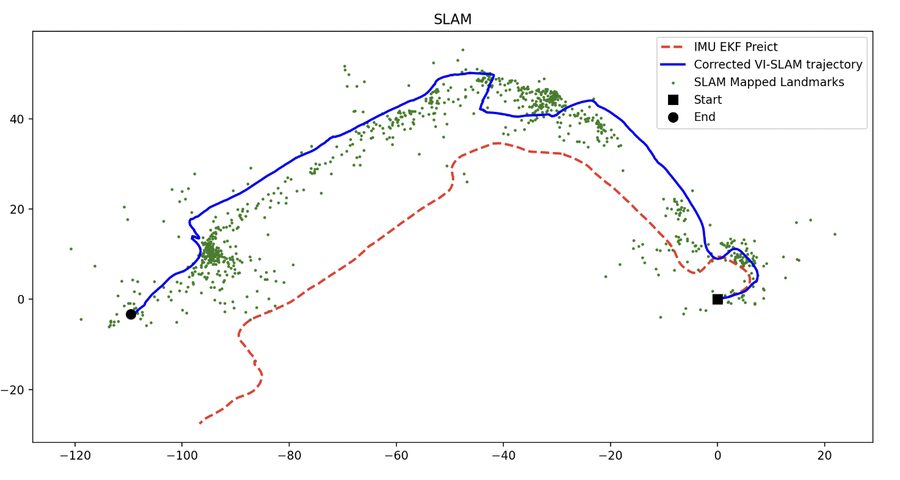
Visual-Inertial SLAM
EKF-based visual-inertial SLAM on Clearpath Jackal data from MIT's campus. Fuses IMU kinematics on SE(3) with stereo camera features to jointly estimate the robot trajectory and 3D landmark map, using sparse covariance slicing to keep updates fast. Also implemented Shi-Tomasi + Lucas-Kanade feature tracking.
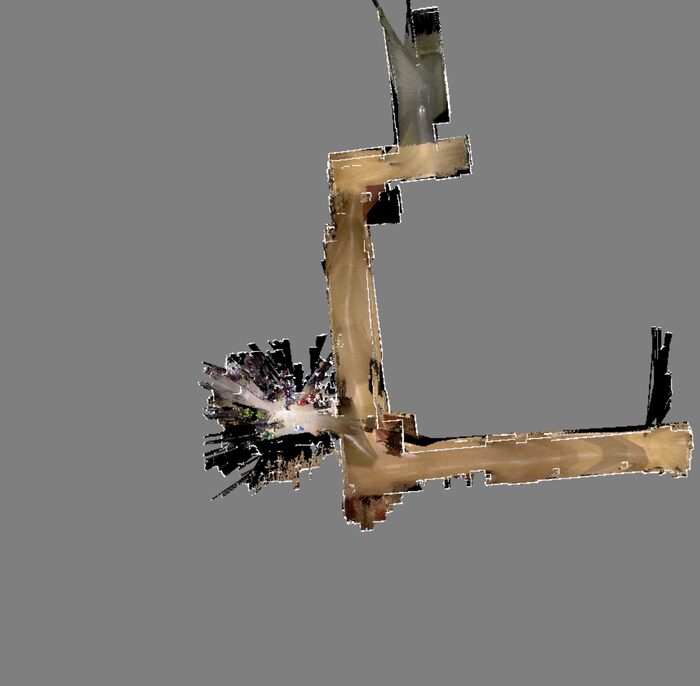
LiDAR-Based SLAM
SLAM for a differential-drive robot using wheel encoders, an IMU, a 2D LiDAR and an RGB-D camera. Dead-reckoned odometry is refined with ICP scan matching, then loop closures are enforced with GTSAM pose graph optimization to produce an occupancy grid and a floor texture map.
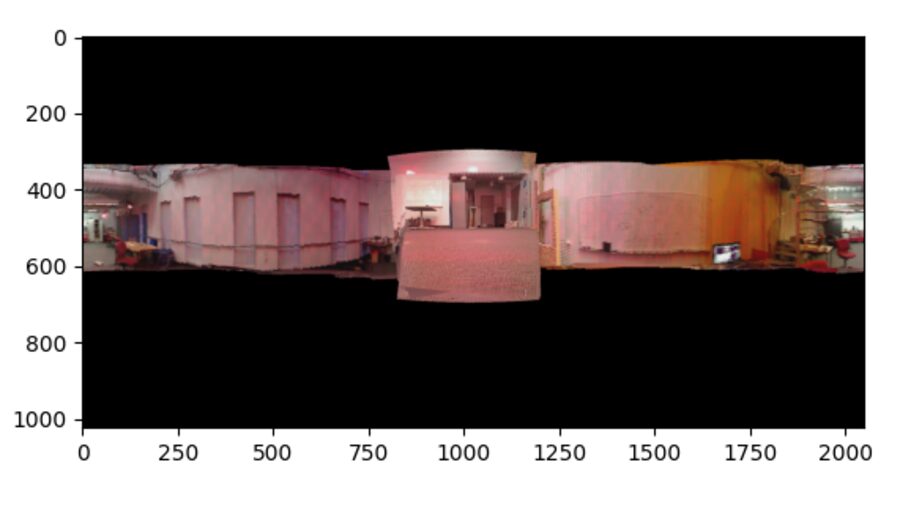
IMU Orientation Estimation & Panorama Stitching
Estimated 3D orientation from IMU data by solving a constrained optimization over unit quaternions with projected gradient descent (PyTorch autograd), validated against VICON ground truth. The estimates were then used to stitch camera images into panoramas via equirectangular projection.
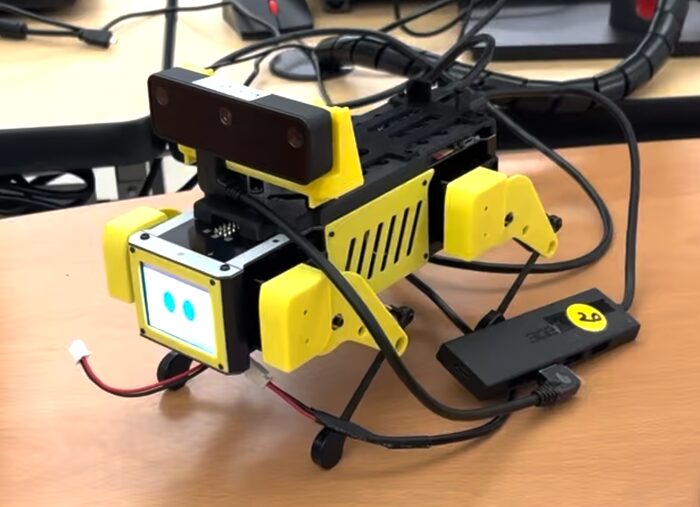
Pupperdoro: An Embodied Study Companion Robot
A Pomodoro timer robot on a MiniPupper 2.0 that keeps students focused by physically separating them from their phones. Using an OAK-D camera, AprilTags, and touch sensors, it detects when the user is distracted and responds with facial and audio emotes, driven by a ROS 2 state machine. I built the "device jail" and the emote audio. We ran a user study comparing it with a digital Pomodoro timer.
Teaching

- Introduction to Robotics (CSE 276A), Fall 2026 with Professor Henrik Christensen
- Prototyping (DSGN 100), Spring 2026 with Professor Scott Klemmer

- Theory of Computation (CSE 105), Fall 2024 with Professor Mia Minnes
- Computer Organization and Systems Programming (CSE 30), Spring 2024 with Professor Keith Muller and Professor Paul Cao
- Calculus III (MATH 10C), Fall 2024 with Professor Yosuf Habib

- Linear Algebra (MATH 18) in Spring 2022, Fall 2022, Winter 2023